
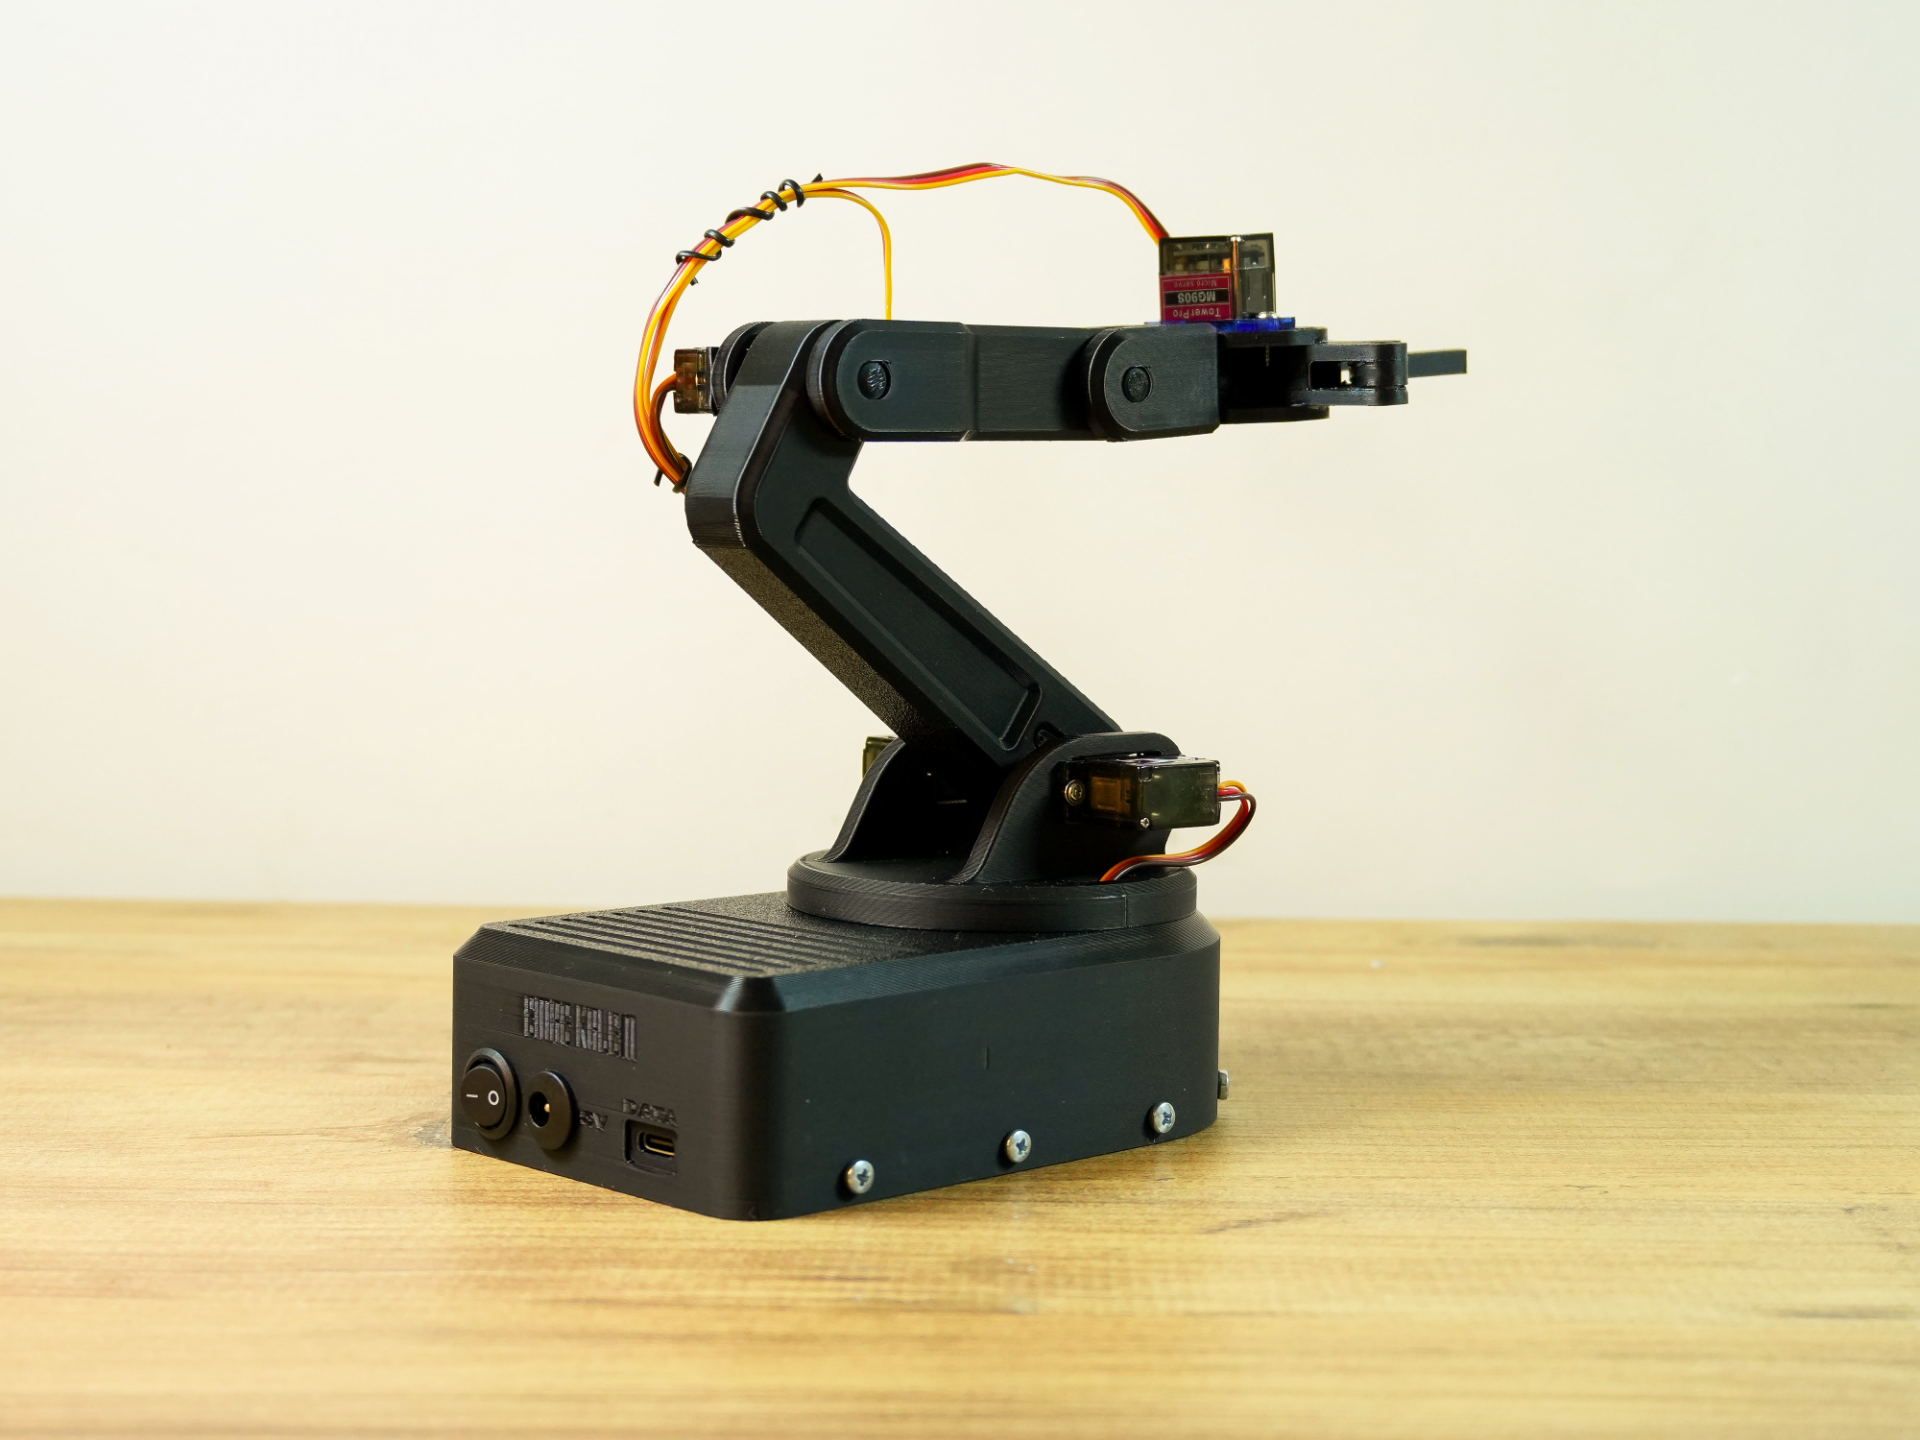
Micro Robot Arm with ESP32 & MG90S
Peso
197g
Tiempo
7h 8m
Precio
Pregunta por WhatsApp por este modelo o uno similar
Te ayudamos a conseguir este diseño o uno parecido, con precio según color y acabado
Las dimensiones dependen del diseño. Confirmamos las medidas exactas por WhatsApp.
Este diseño es de su creador en MakerWorld y se muestra solo como referencia. Tecnoprints no es dueño del modelo ni de su licencia.
Descripción
This project presents a 5-DOF robot arm developed from scratch, together with a web-based control interface designed to operate it. The interface runs from a single HTML file and requires no additional software installation. Assembly & Test Video: Robot Arm • 5-DOF • ESP32 microcontroller running custom firmware • Communication via USB serial or Wi-Fi (WebSocket) Control Interface • Real-time 3D visualization that mirrors the arm’s movement • Direct joint control, as well as end-point control through forward and inverse kinematics • Jog panel, inspired by Klipper/Mainsail, for directional end-point movement • Import of custom STL parts, with assignment to joints and individual hide/delete options • Pose recording and reordering, per-step duration settings, and program export/import • Fully customizable keyboard shortcuts, including per-joint keys, Home, and Emergency Stop • Mobile and touchscreen support • Project backup (export/import) and customizable interface themes Required Files: https://drive.google.com/file/d/1VNj0mdC4_HoTYbe_FGJ5kCR1J_W0uxR0/view?usp=sharing Circuit Schematic: https://app.cirkitdesigner.com/project/b666176c-4019-4d2a-8222-8b6857c6c086 Required Parts: • 1 X ESP32-C6-DEV-KIT-NX • 1 X PCA9685 PWM Servo Motor Driver • 6 X MG90S 180 Degree Servo Motor • 2 X 30cm Servo Extender Cable • 1 X Panel Mount 2.1mm Barel Jack • 1 X KCD11 Round Rocker Switch • 5V 5A Power Supply • Jumper Cables • M3x6mm & M3x8mm Screws
Tags
Diseñador
Emre Kalem